01Active
Earth
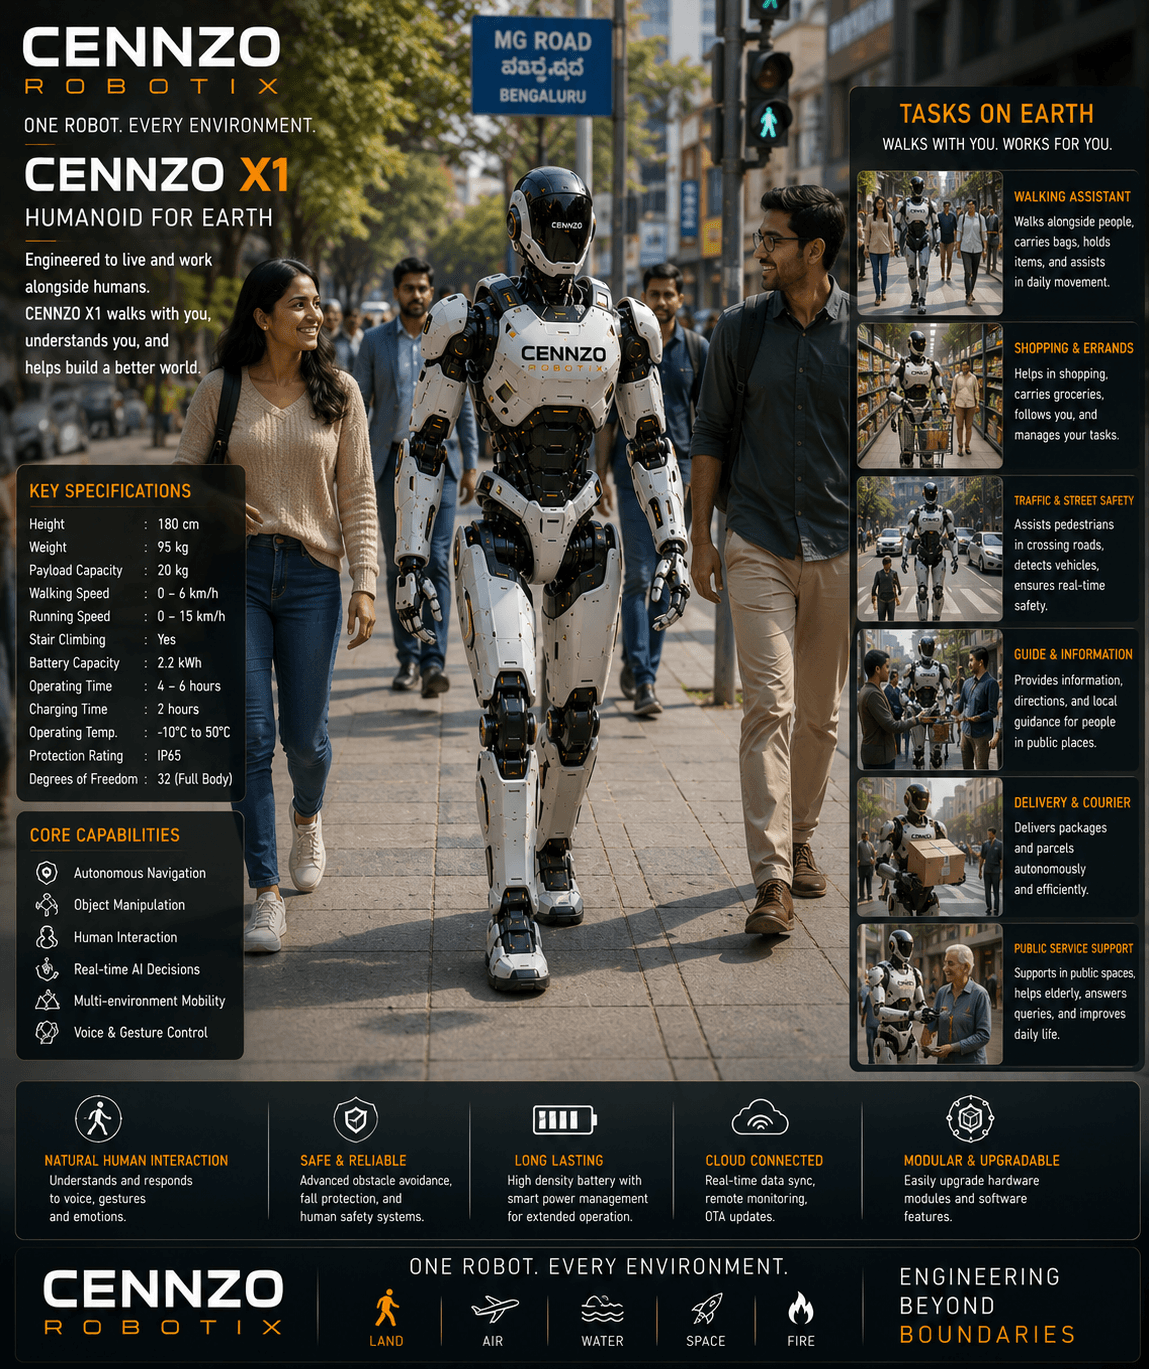
Navigate industrial, infrastructure, logistics and disaster environments with human-compatible mobility and manipulation
WAFEE — Unified Multi-Environment Humanoid Platform
WAFEE is an engineering platform under development
0
cm stature
Human-scale form factor built for a world sized for people
0
mission domains
One architecture targeting land, sea, fire, air and space
0
core capabilities
Mobility, manipulation, perception, autonomy and more
0
system attributes
From electric actuation to continuous health monitoring
The Platform
WAFEE is a 178 cm-class humanoid robotic platform engineered around a modular architecture for mobility, manipulation, perception and autonomous operation
Designed as a platform rather than a single-purpose machine, WAFEE can evolve across industries, mission profiles and future generations of robotic intelligence
0 cm
Humanoid-Class Height
0
Mission Environments
0
Core Platform Attributes
Design Philosophy
Built around people, tools and workflows that already exist
Hardware and software designed to evolve mission by mission
Perception and autonomy that turn raw data into decisions
Protected, robust and persistent when conditions turn hostile
An architecture that grows sharper with every generation
System Status
Concept DemoLatency
12ms
Confidence
98.4%
VISUAL CONCEPT — NOT LIVE TELEMETRY
Every sensor array is engineered to keep WAFEE aware— even when the world goes dark
Mission Domains
Navigate industrial, infrastructure, logistics and disaster environments with human-compatible mobility and manipulation
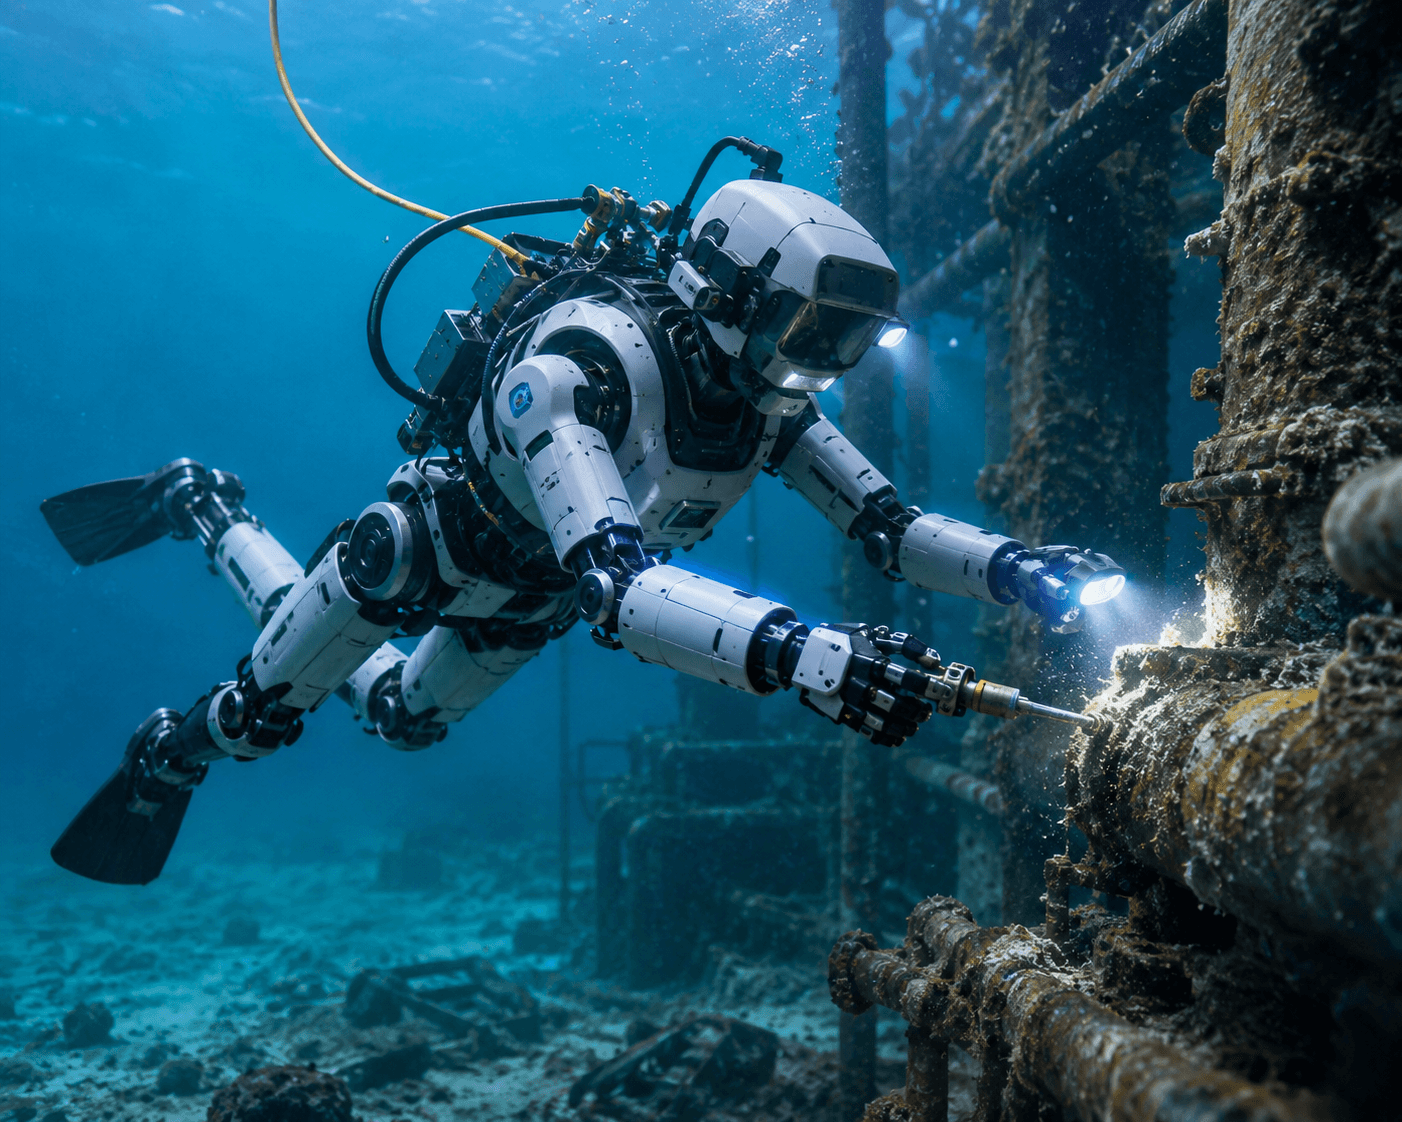
Enable inspection, intervention and support operations in aquatic environments through a protected robotic architecture
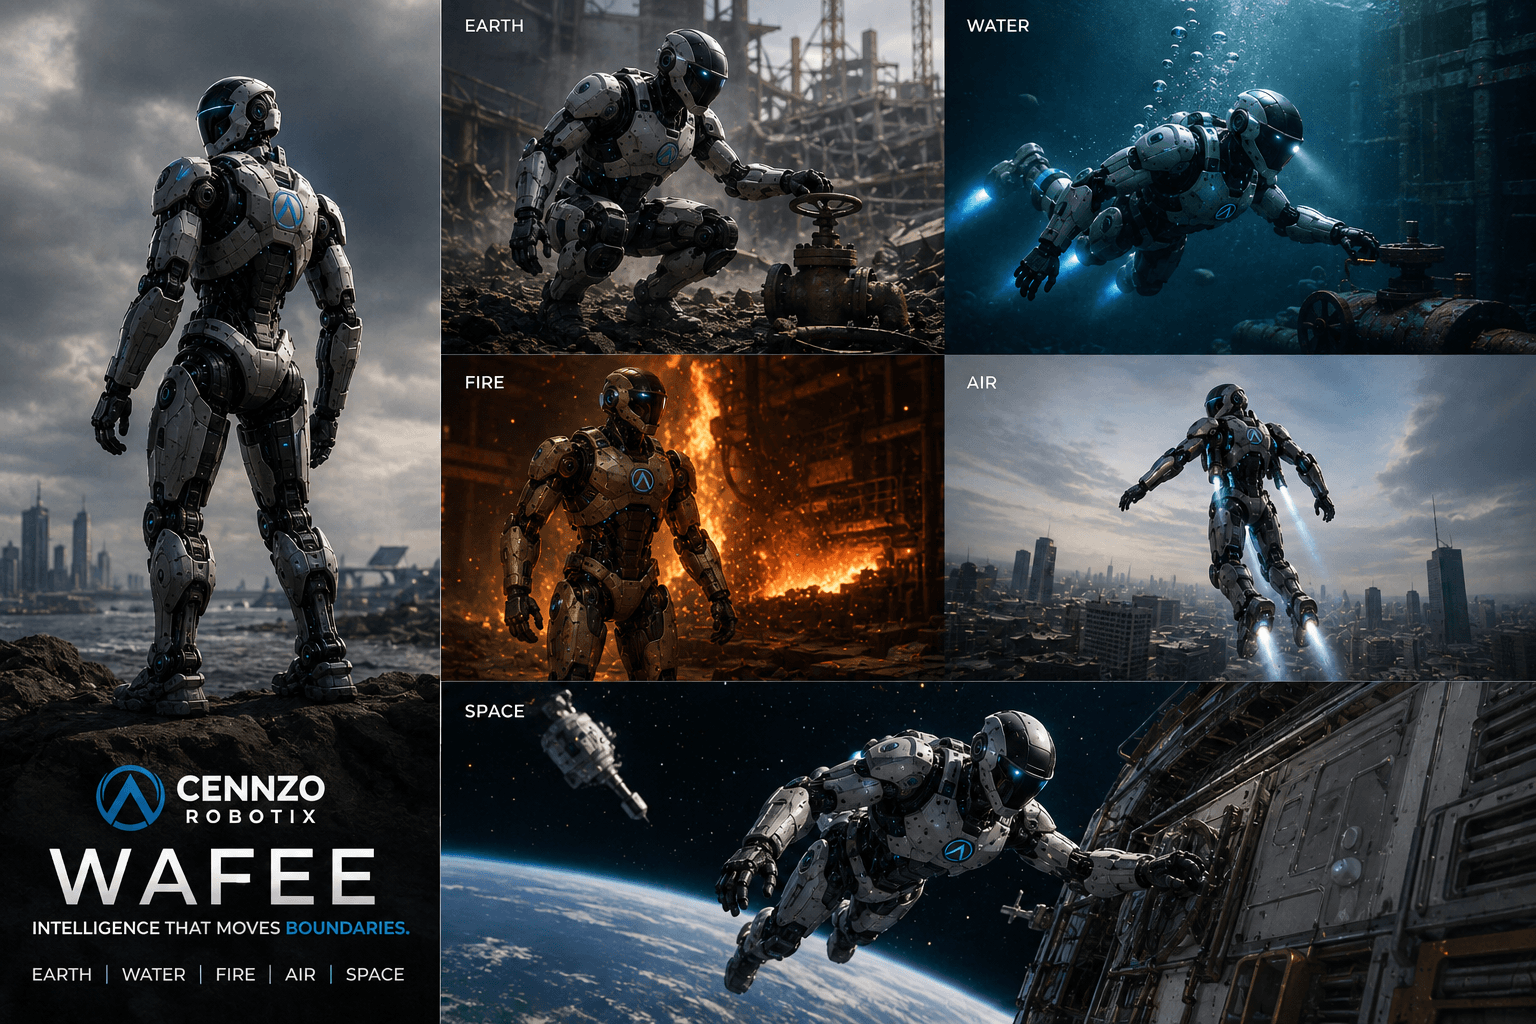
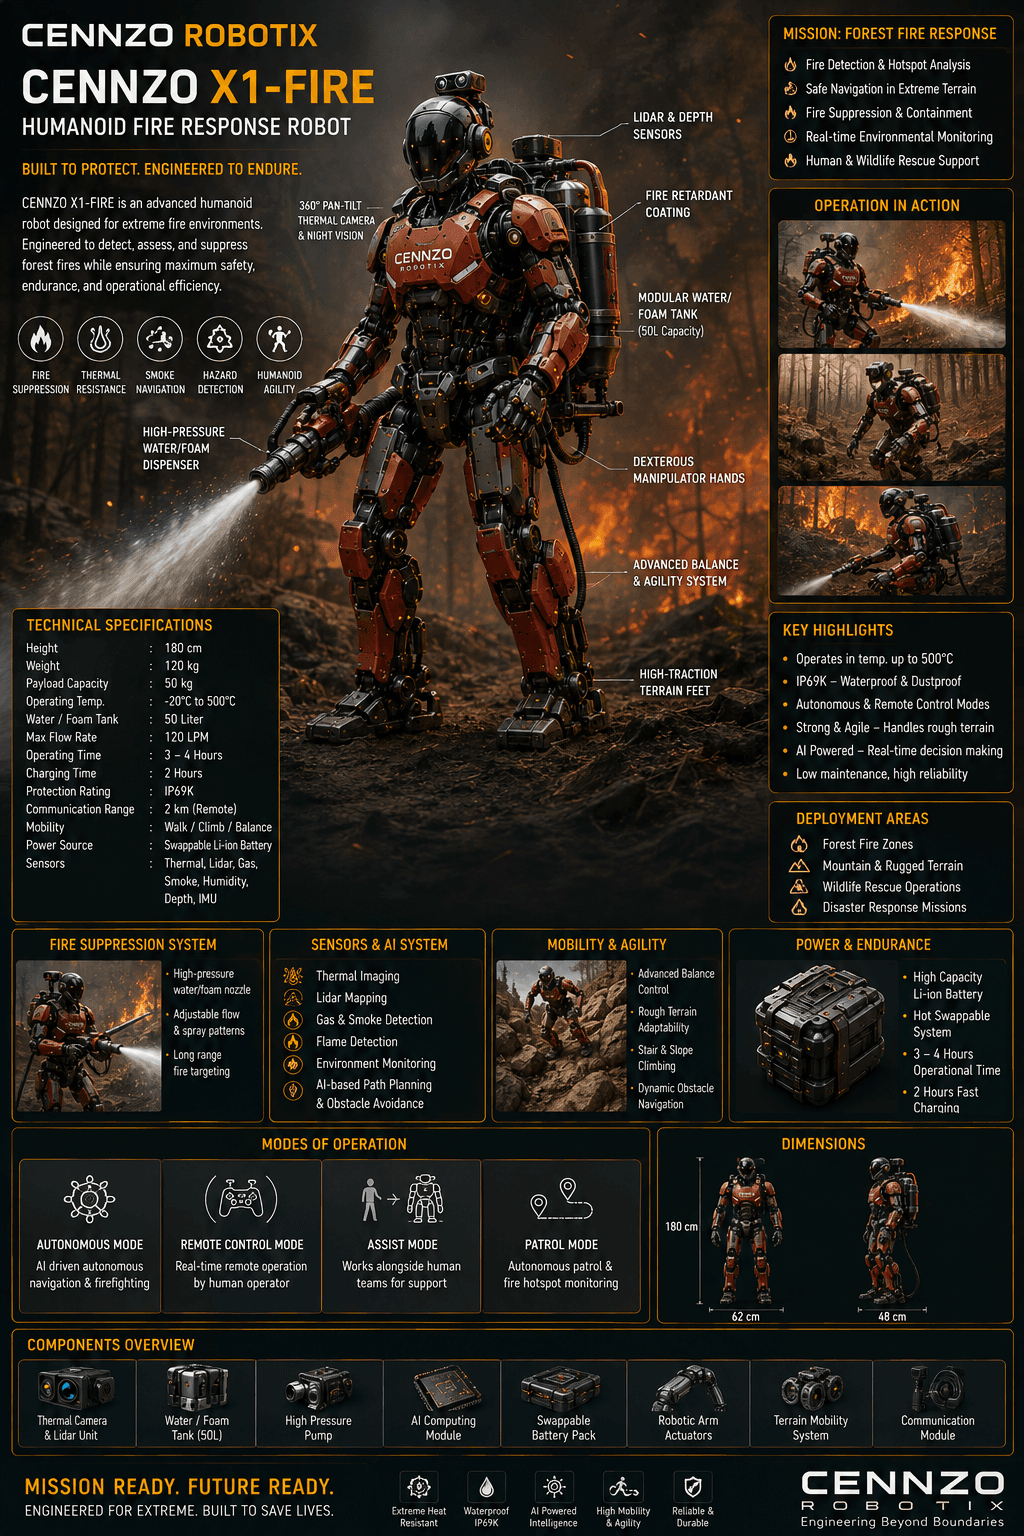
Support operations in high-temperature and hazardous zones where direct human access is limited
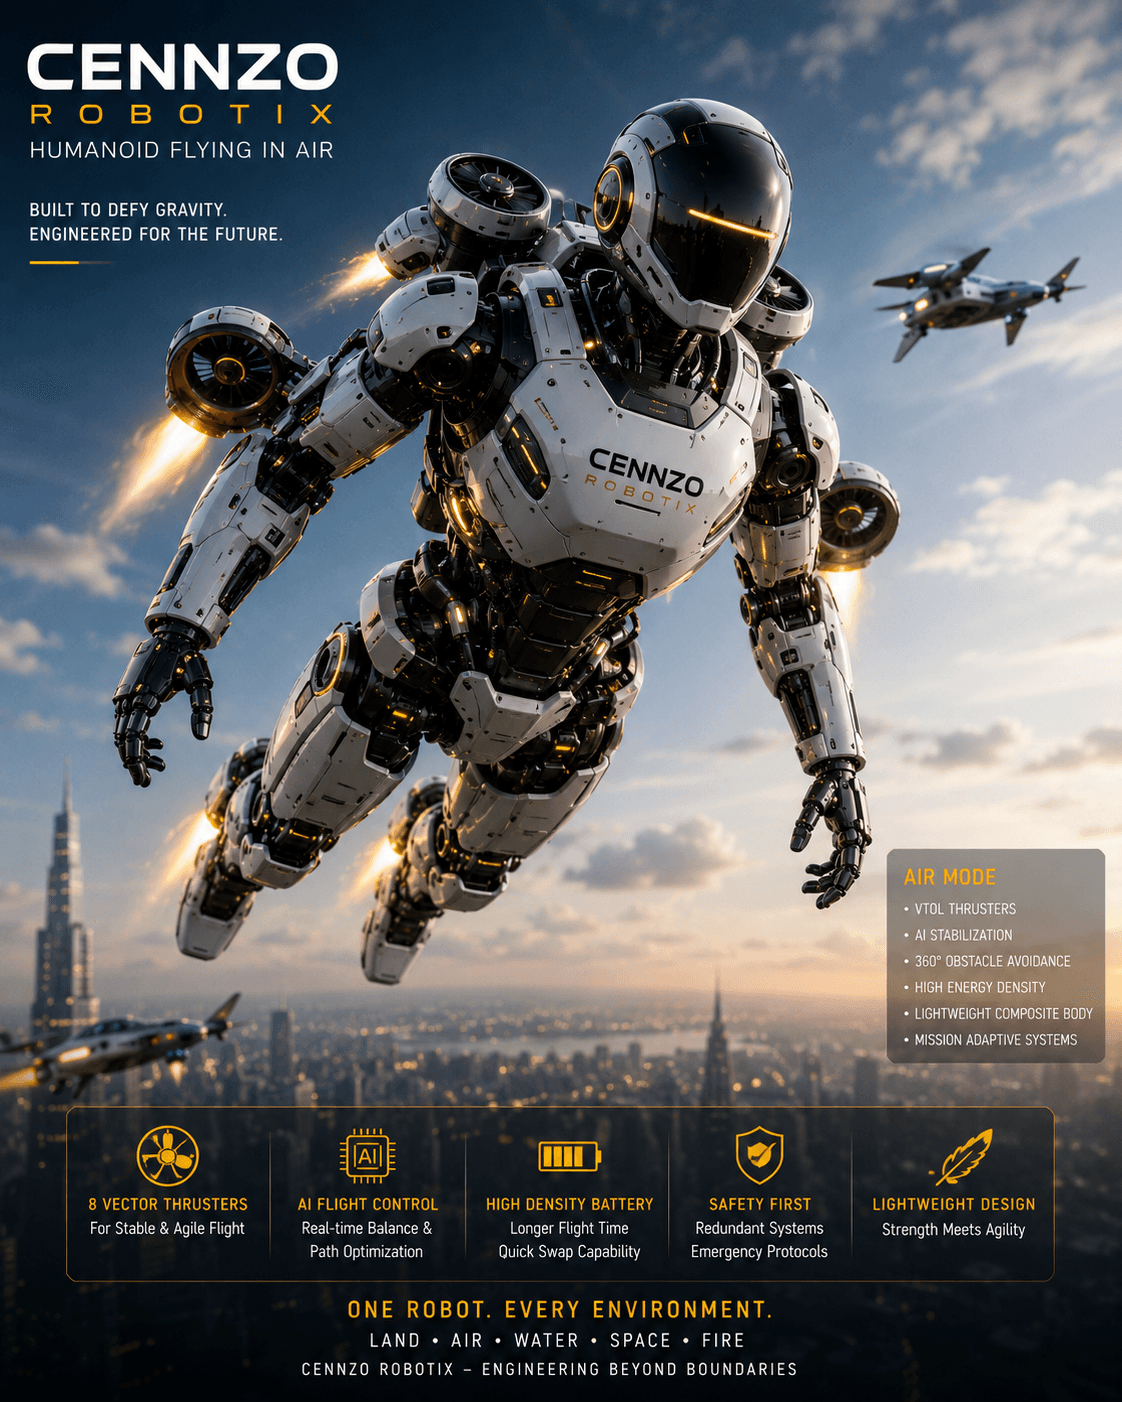
Operate across elevated, exposed and difficult-to-access environments using intelligent mobility and mission-specific systems
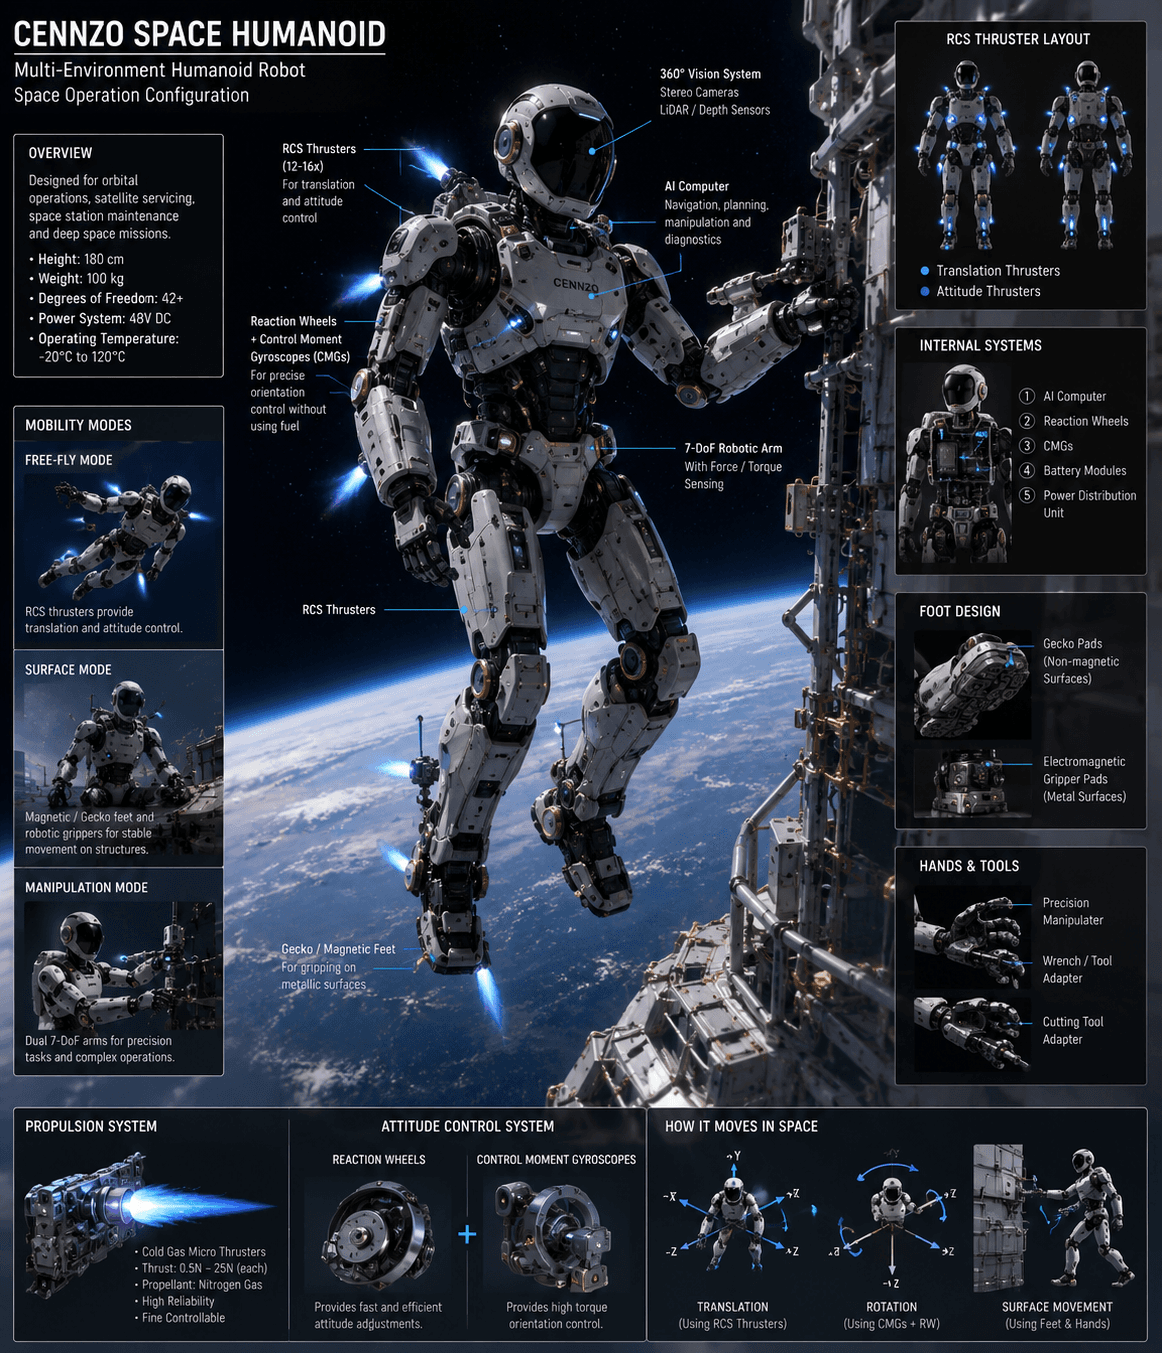
Create a pathway toward robotic operations in vacuum, extreme radiation and off-world environments
The Journey — Five Environments
Scroll to travel the roadmap — Earth to Space
01 / 05 — Industrial · Infrastructure · Disaster
Navigate industrial, infrastructure, logistics and disaster environments with human-compatible mobility and manipulation
02 / 05 — Marine · Offshore · Subsurface
Enable inspection, intervention and support operations in aquatic environments through a protected robotic architecture
03 / 05 — High-Temperature · Hazardous Zones
Support operations in high-temperature and hazardous zones where direct human access is limited
04 / 05 — Elevated · Exposed · Access-Limited
Operate across elevated, exposed and difficult-to-access environments using intelligent mobility and mission-specific systems
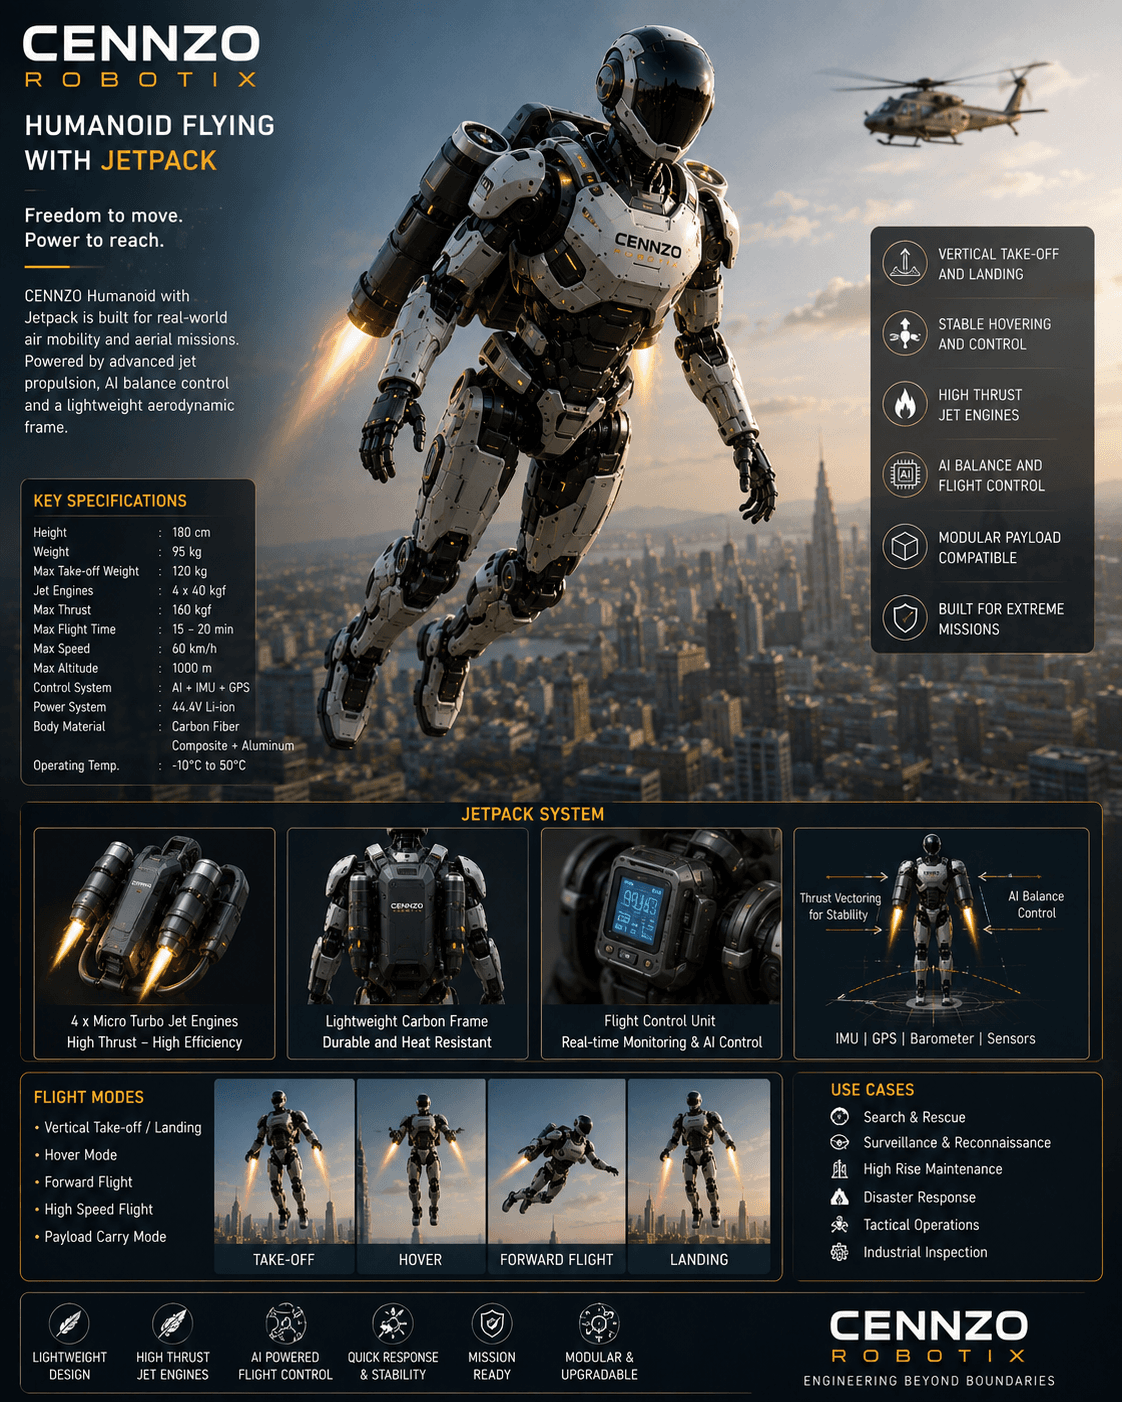
05 / 05 — Vacuum · Radiation · Off-World
Create a pathway toward robotic operations in vacuum, extreme radiation and off-world environments
WAFEE’s multi-environment vision represents a long-term engineering roadmap. Individual environmental capabilities depend on mission-specific configuration, validation and certification
Reference Platform
Published values represent the reference platform architecture. Performance figures are design targets unless explicitly identified as validated results
Capabilities
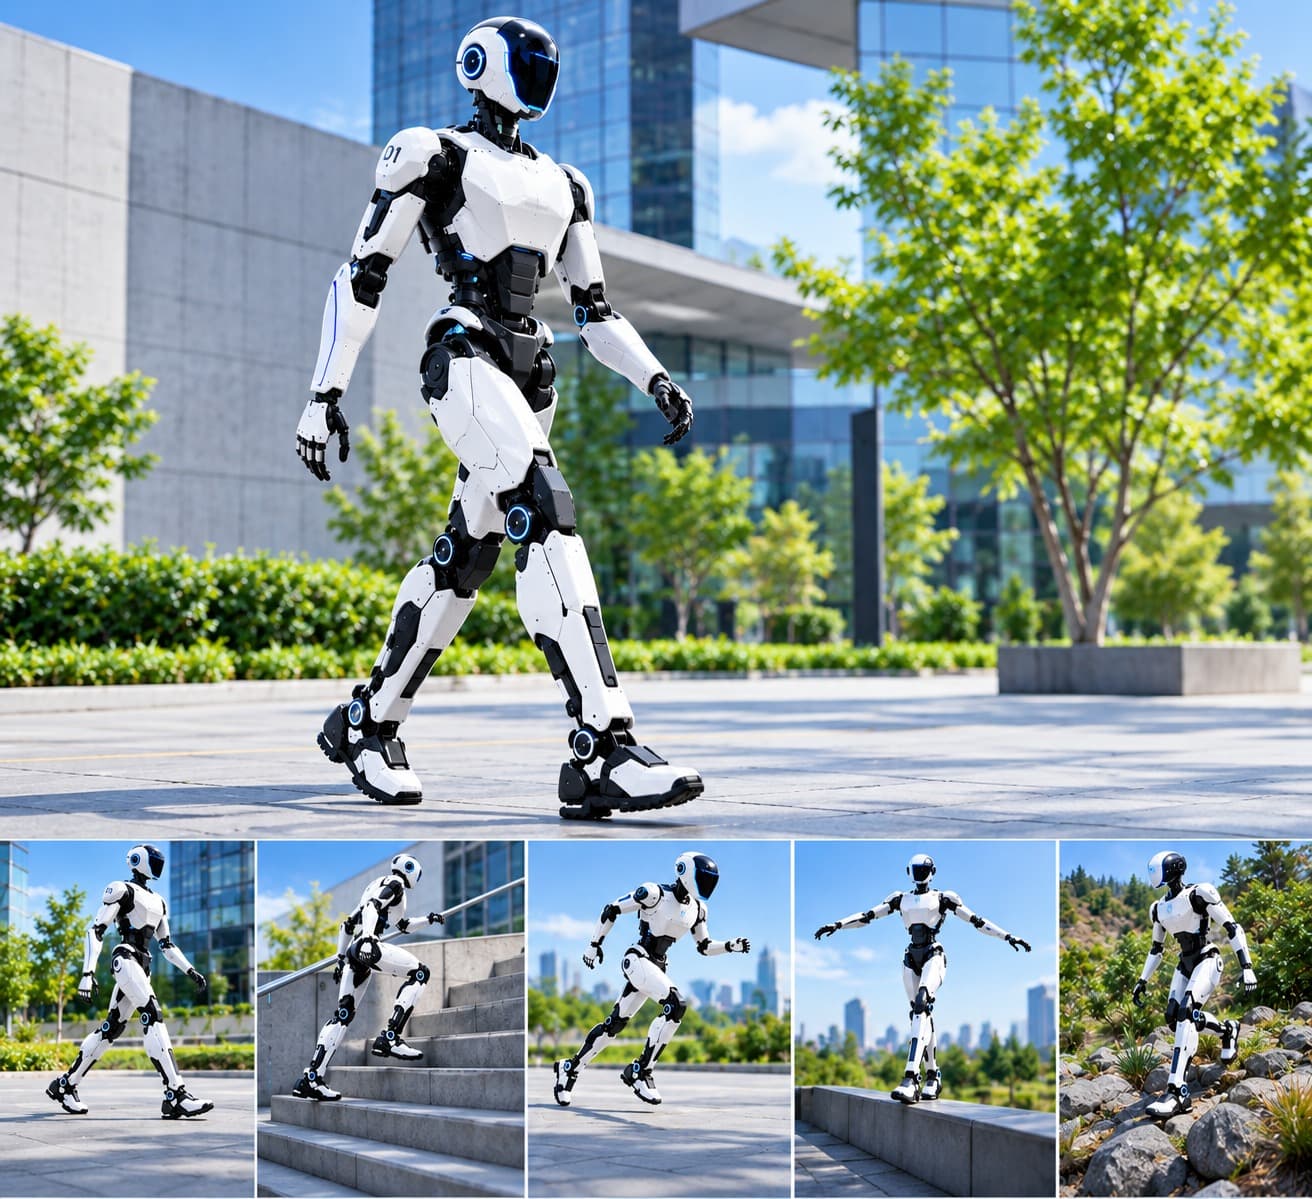
01
Dynamic walking, balance, terrain adaptation and controlled whole-body movement
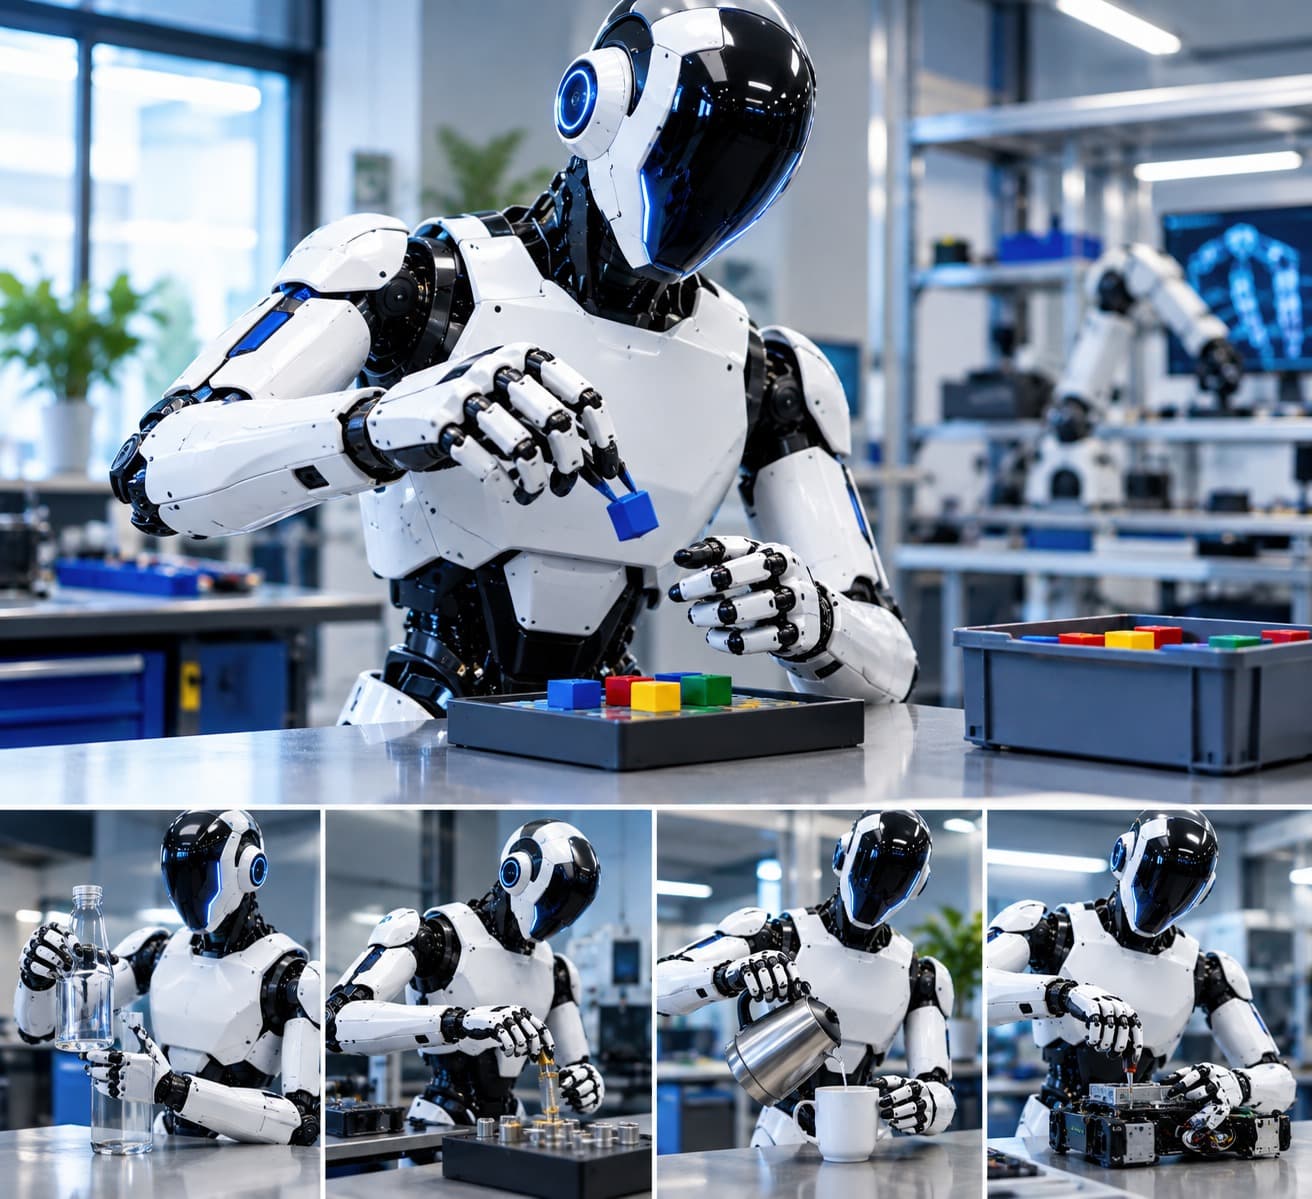
02
Human-compatible arms and hands designed for interaction with tools, equipment and infrastructure
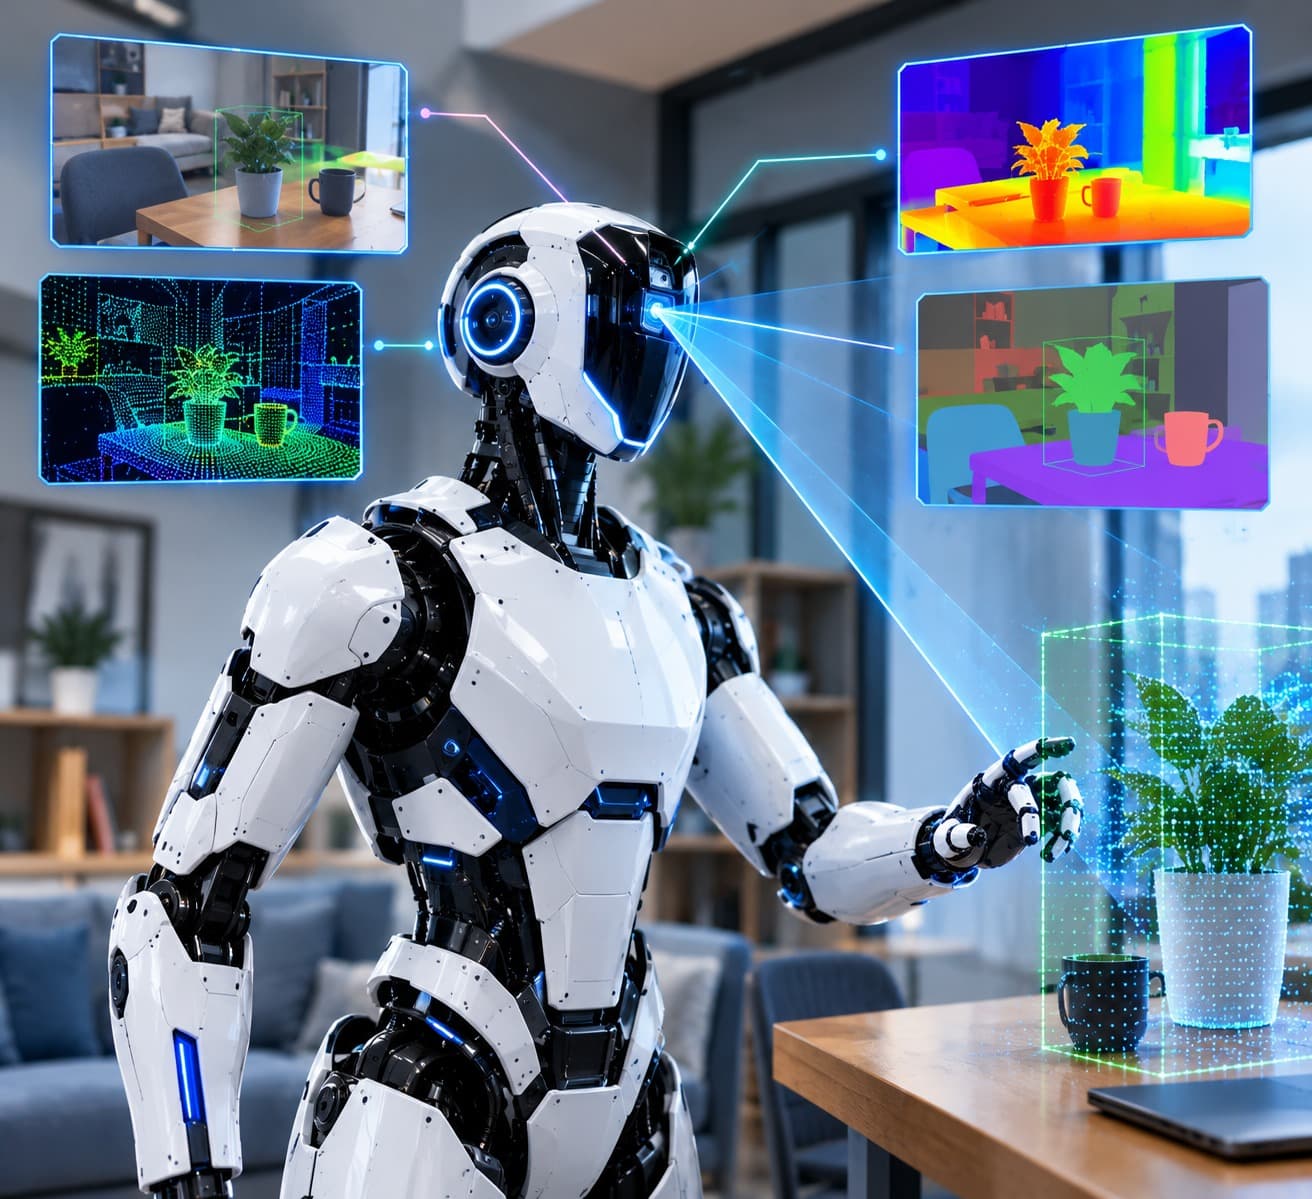
03
Real-time understanding of surroundings using multiple sensing modalities
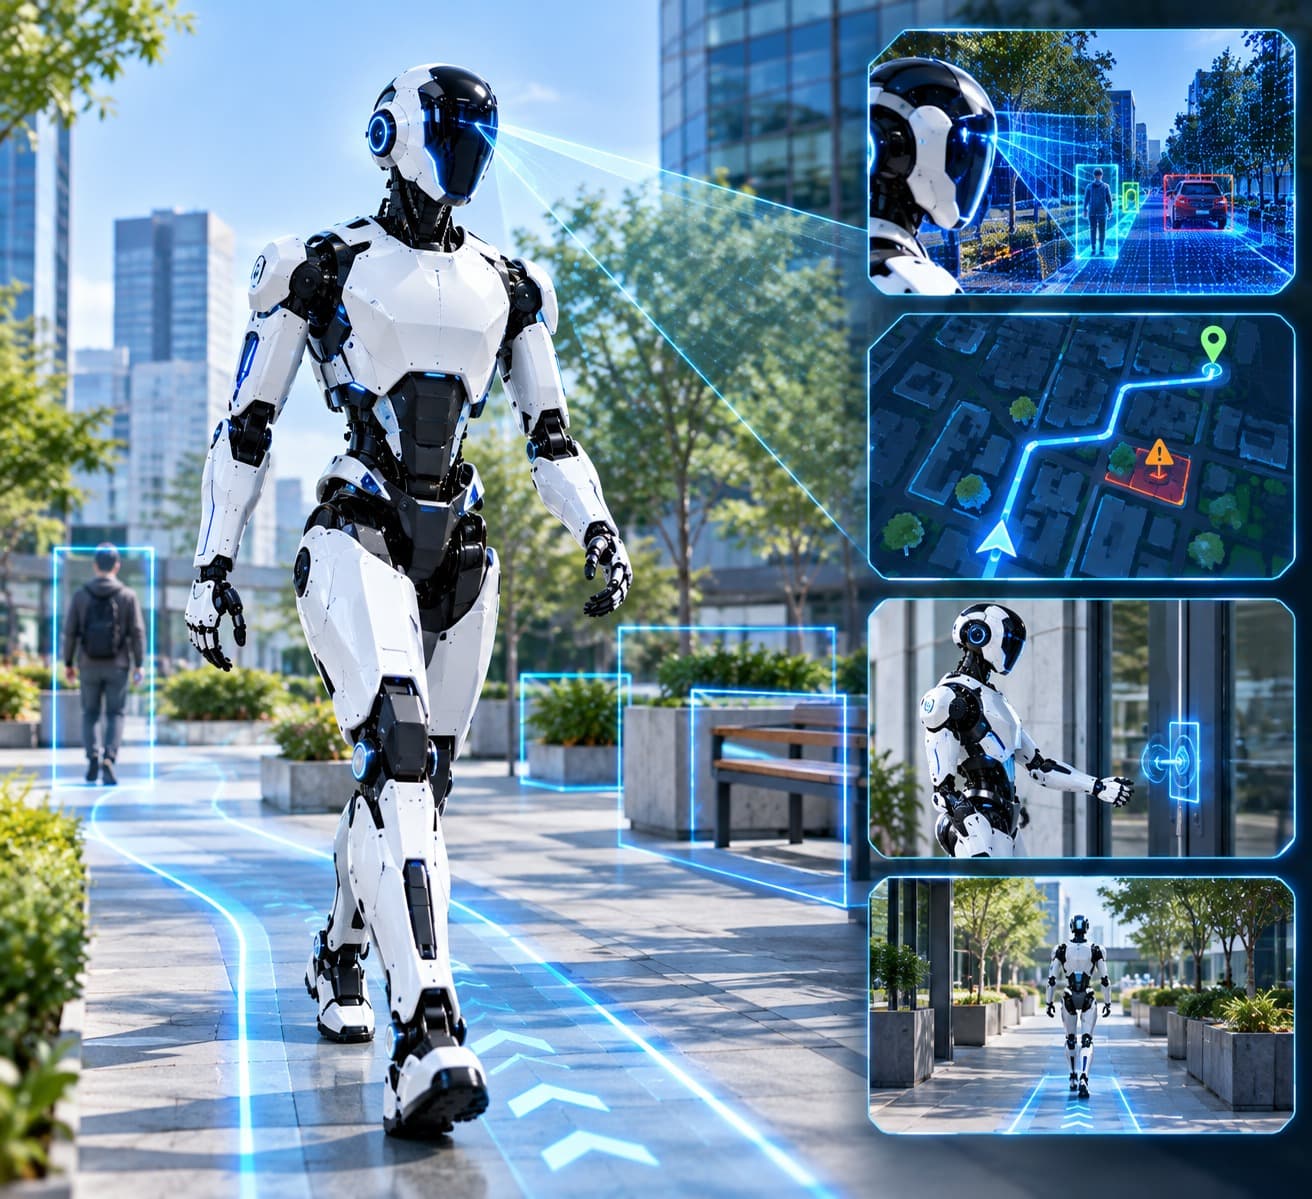
04
Mission planning, navigation, obstacle handling, system monitoring and intelligent decision support
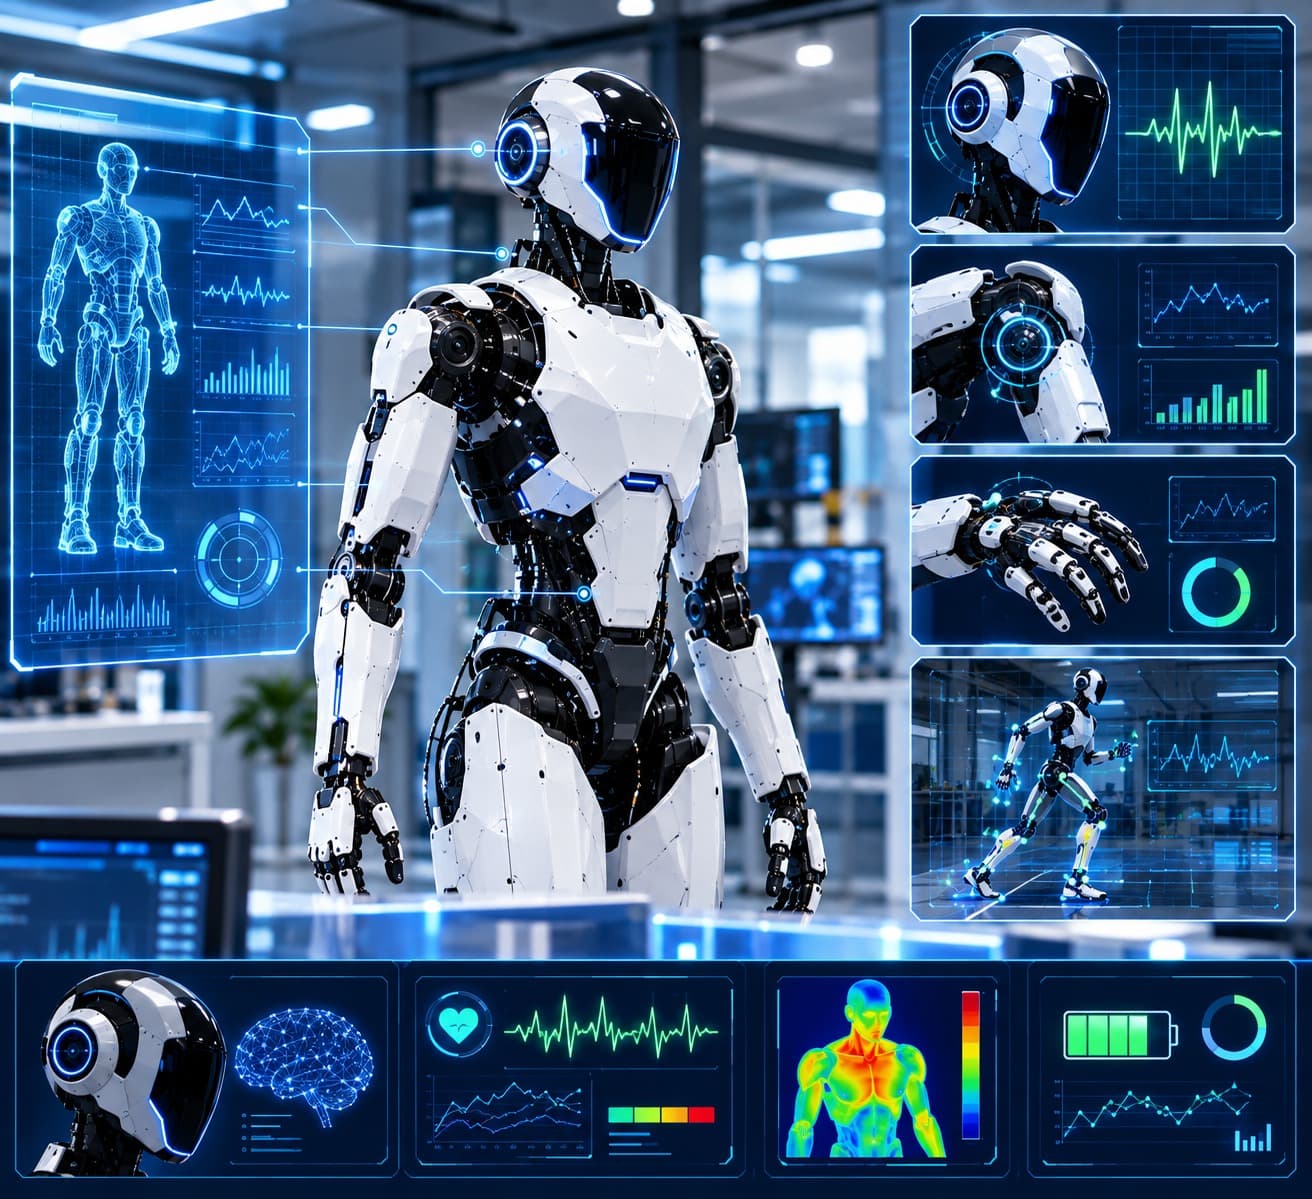
05
Remote human control for situations where supervised operation is preferred or required
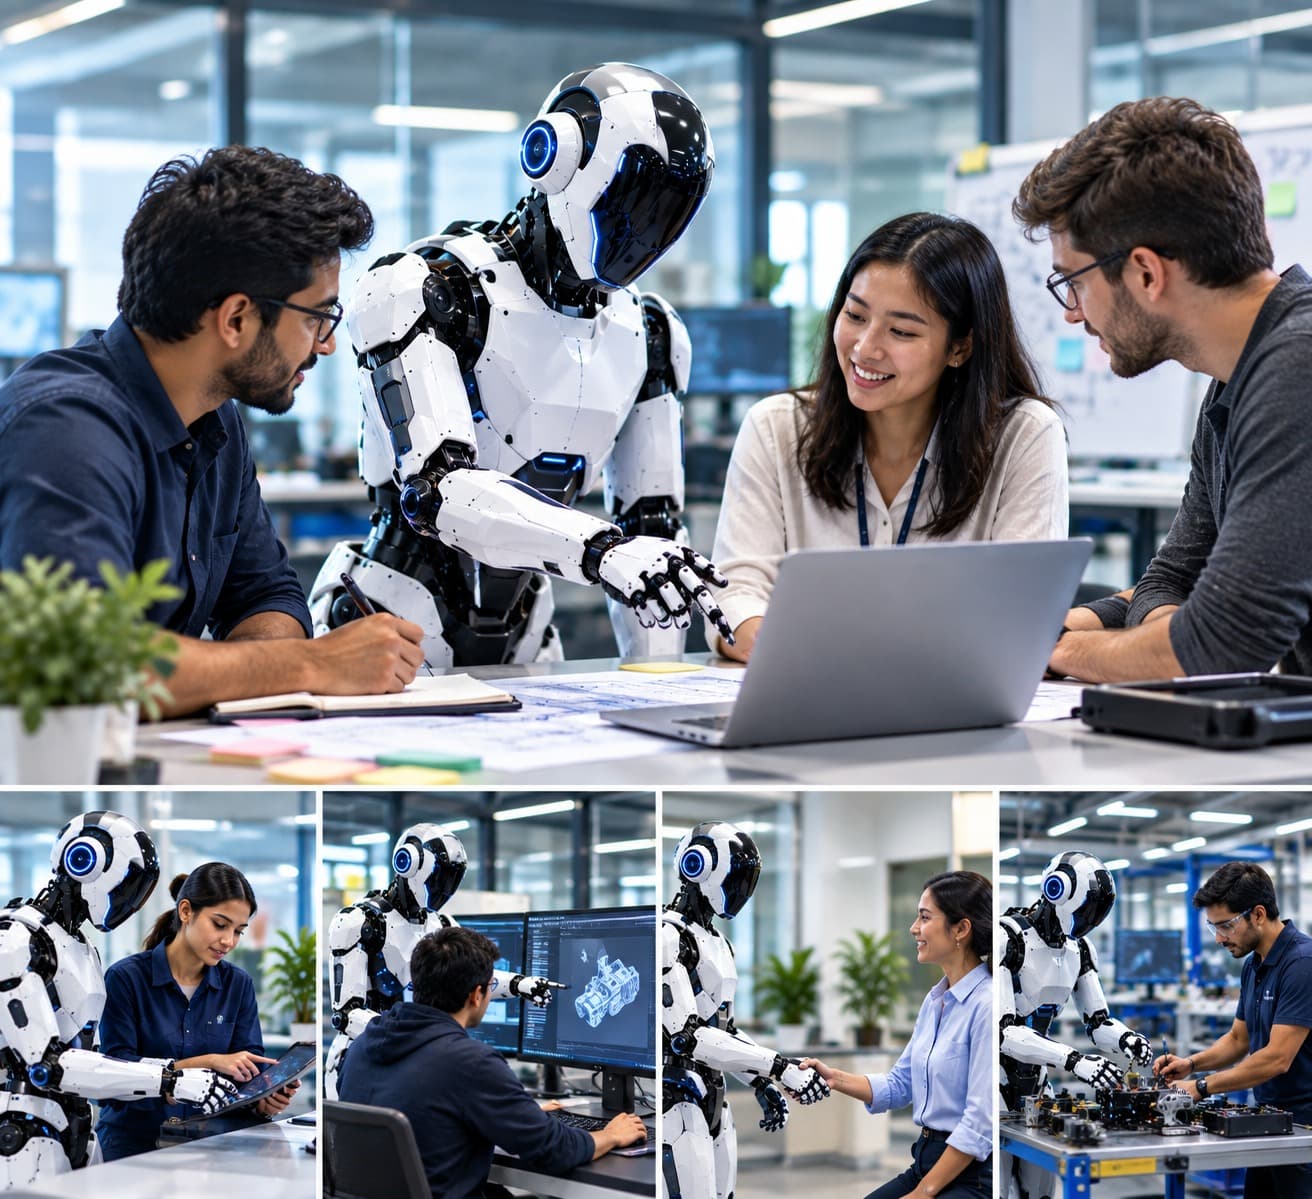
06
Designed to work around humans, tools and existing infrastructure
WAFEE is an engineering platform under development. Environmental claims will be released progressively after controlled laboratory testing, subsystem qualification and full-system validation
Cennzo Robotix
See how WAFEE adapts across mission configurations